If one robot has mapped a room, could another use some of that information? A shared spatial database is an ambitious idea, but the useful information…
View more
A remote expert may have a limited time to review a live scene.
View more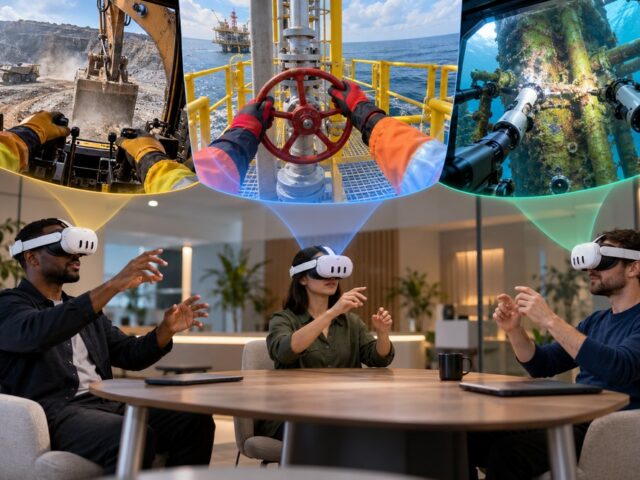
Several live viewpoints could give a coordination team different pieces of a developing scene.
View more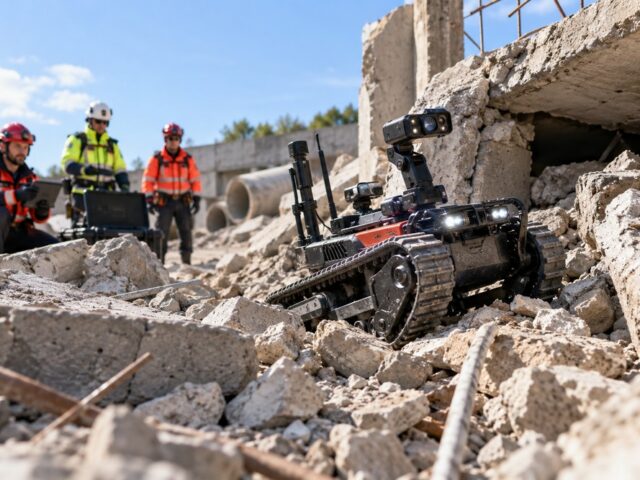
A robot that pauses at the right time may be more useful than one that confidently continues in the wrong direction.
View moreRemote robot operation could let a human inspect a machine’s view and guide a supported action from elsewhere.
View more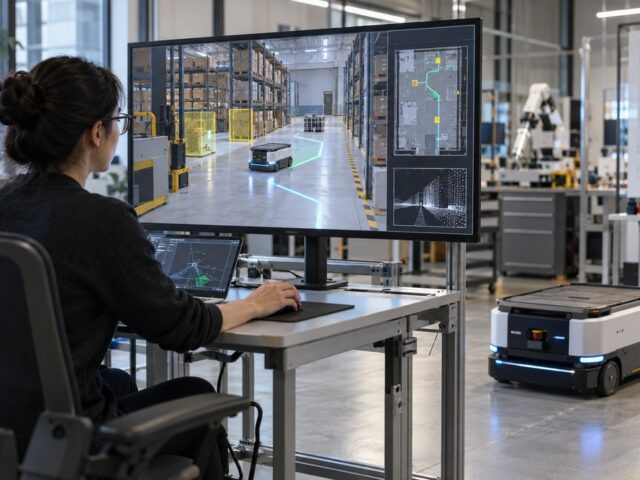
Some situations are difficult to collect repeatedly in the real world.
View moreA robot completing a virtual task is a promising demonstration, not the end of testing.
View moreSim-to-real transfer concerns taking learning or behaviour developed in simulation into a physical system.
View moreA virtual robot school could contain many versions of a task: different rooms, object positions and interruptions.
View moreA construction site does not stay still.
View moreA rescue robot may need to move through spaces that change unpredictably.
View more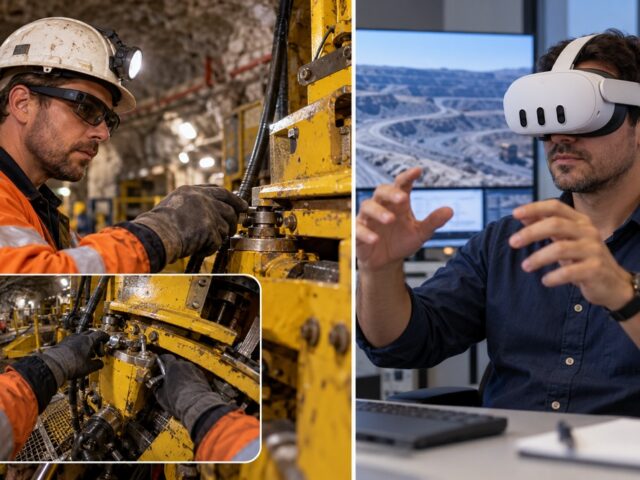
An underground inspection robot needs more than a destination on a map.
View moreMoving supplies between hospital departments is a different problem from providing patient care.
View moreA warehouse brings together shelves, routes, people and moving work.
View moreA digital building model could support more than one audience.
View moreA digital room is only useful while its assumptions remain relevant.
View moreImagine a domestic robot arriving with some knowledge of the layout it will encounter.
View moreA robot foundation model is intended to support a broader range of behaviours than a system trained for one narrow example.
View moreA practical robot task may involve several kinds of information at once.
View moreEmbodied reasoning is about working out what to do in a physical setting.
View more
Lets leap into the future